5-DOF Robotic Hand
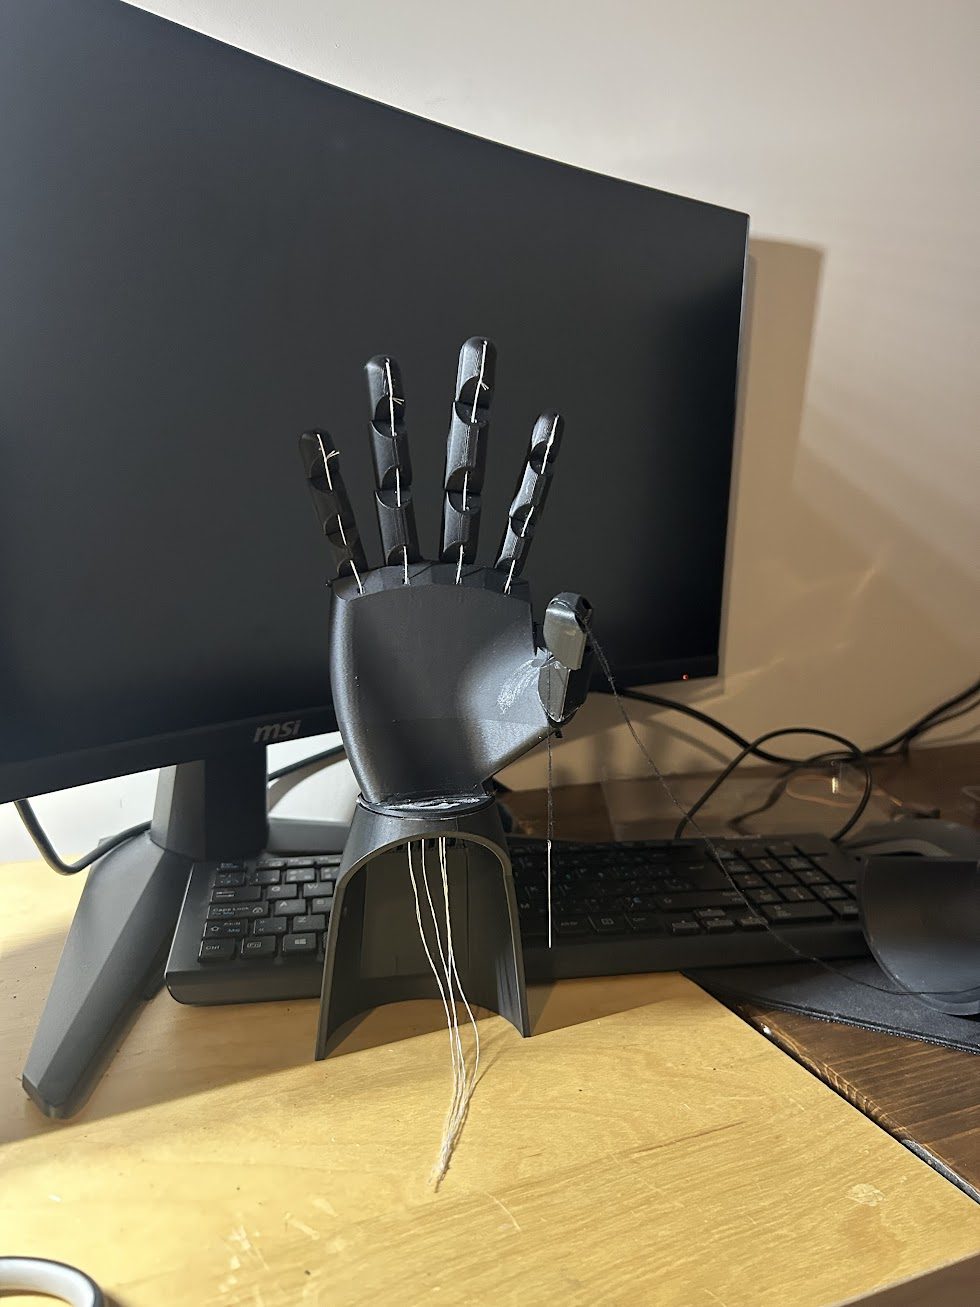
A 3D-printed robotic hand that copies your finger movements in real time.
overview
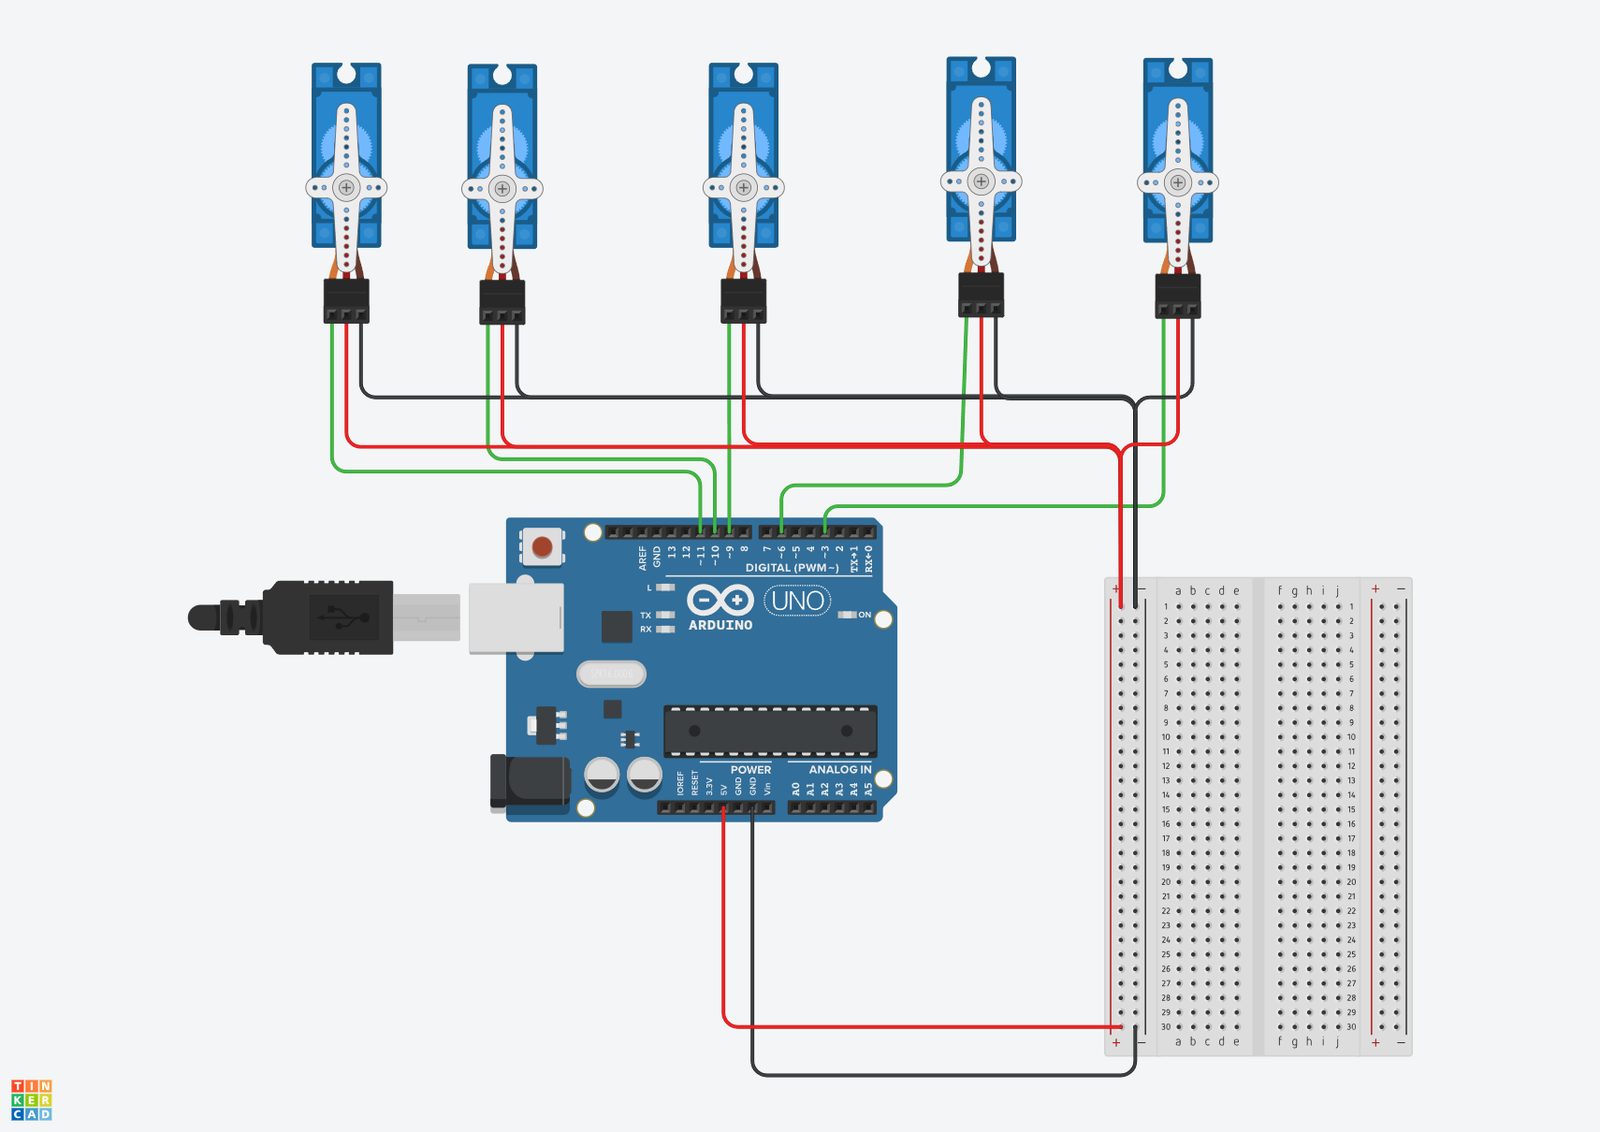
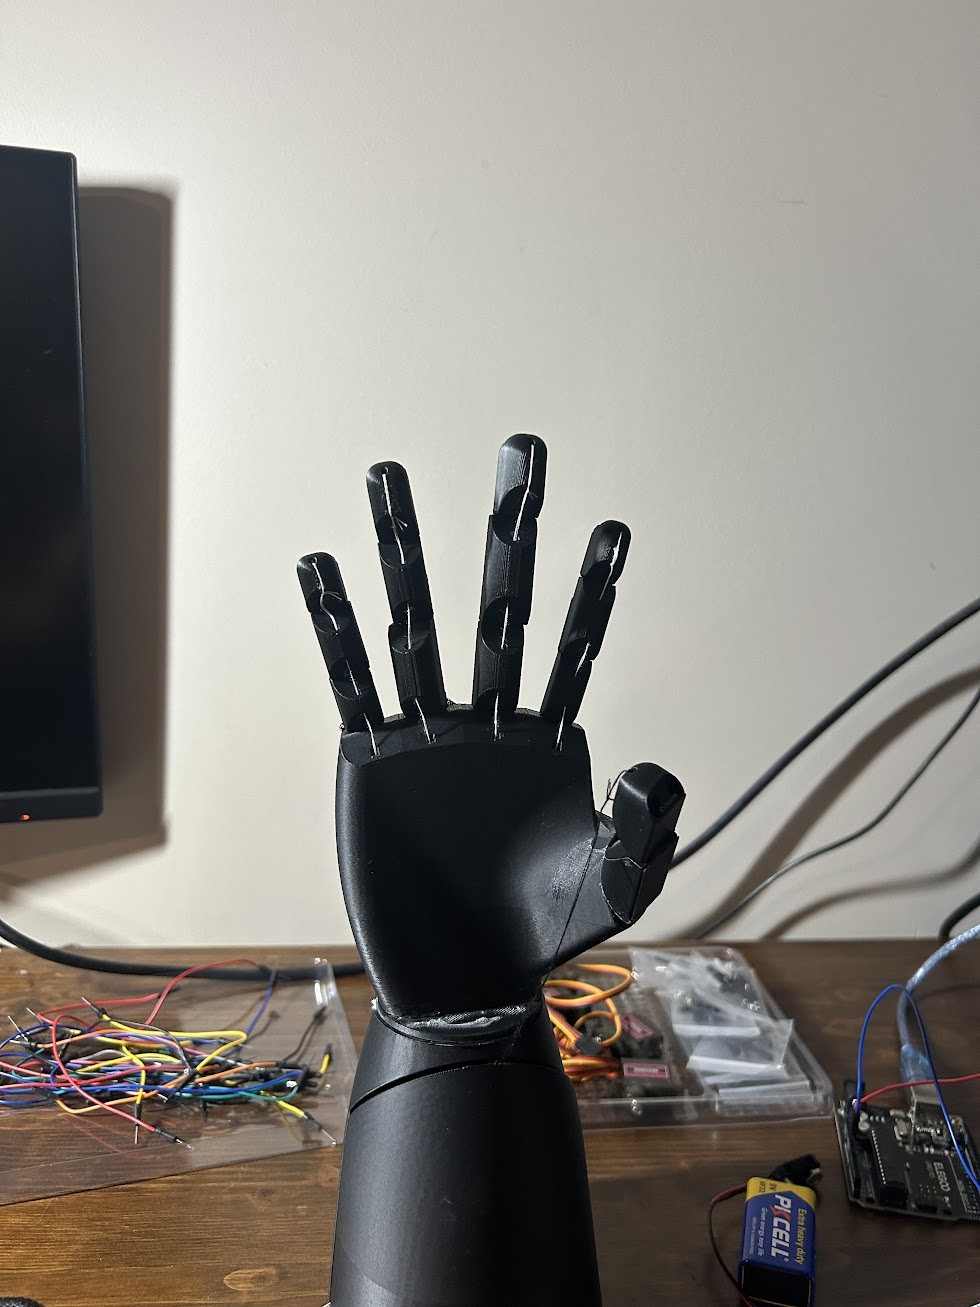
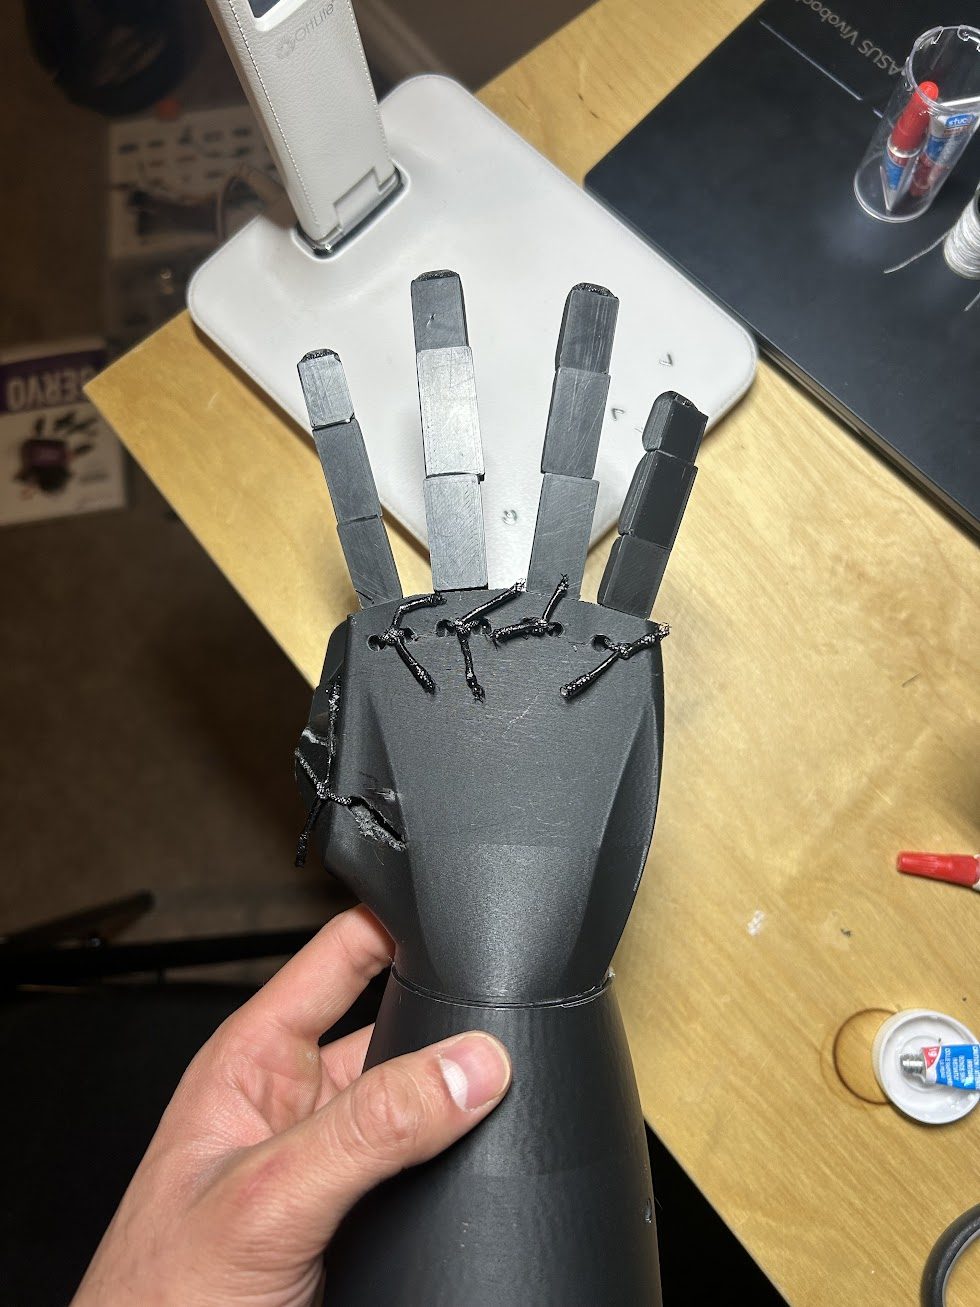
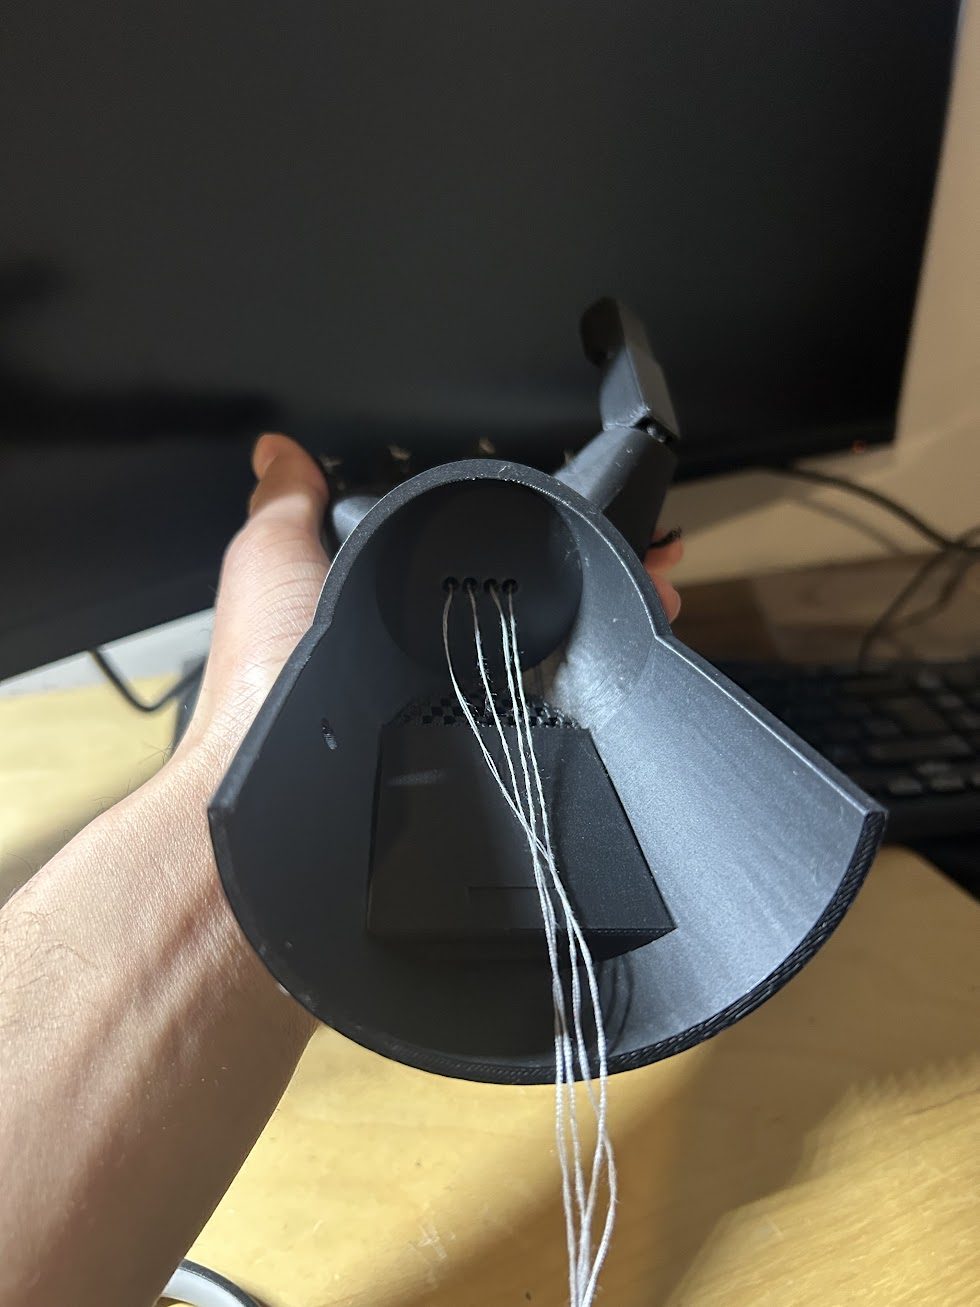
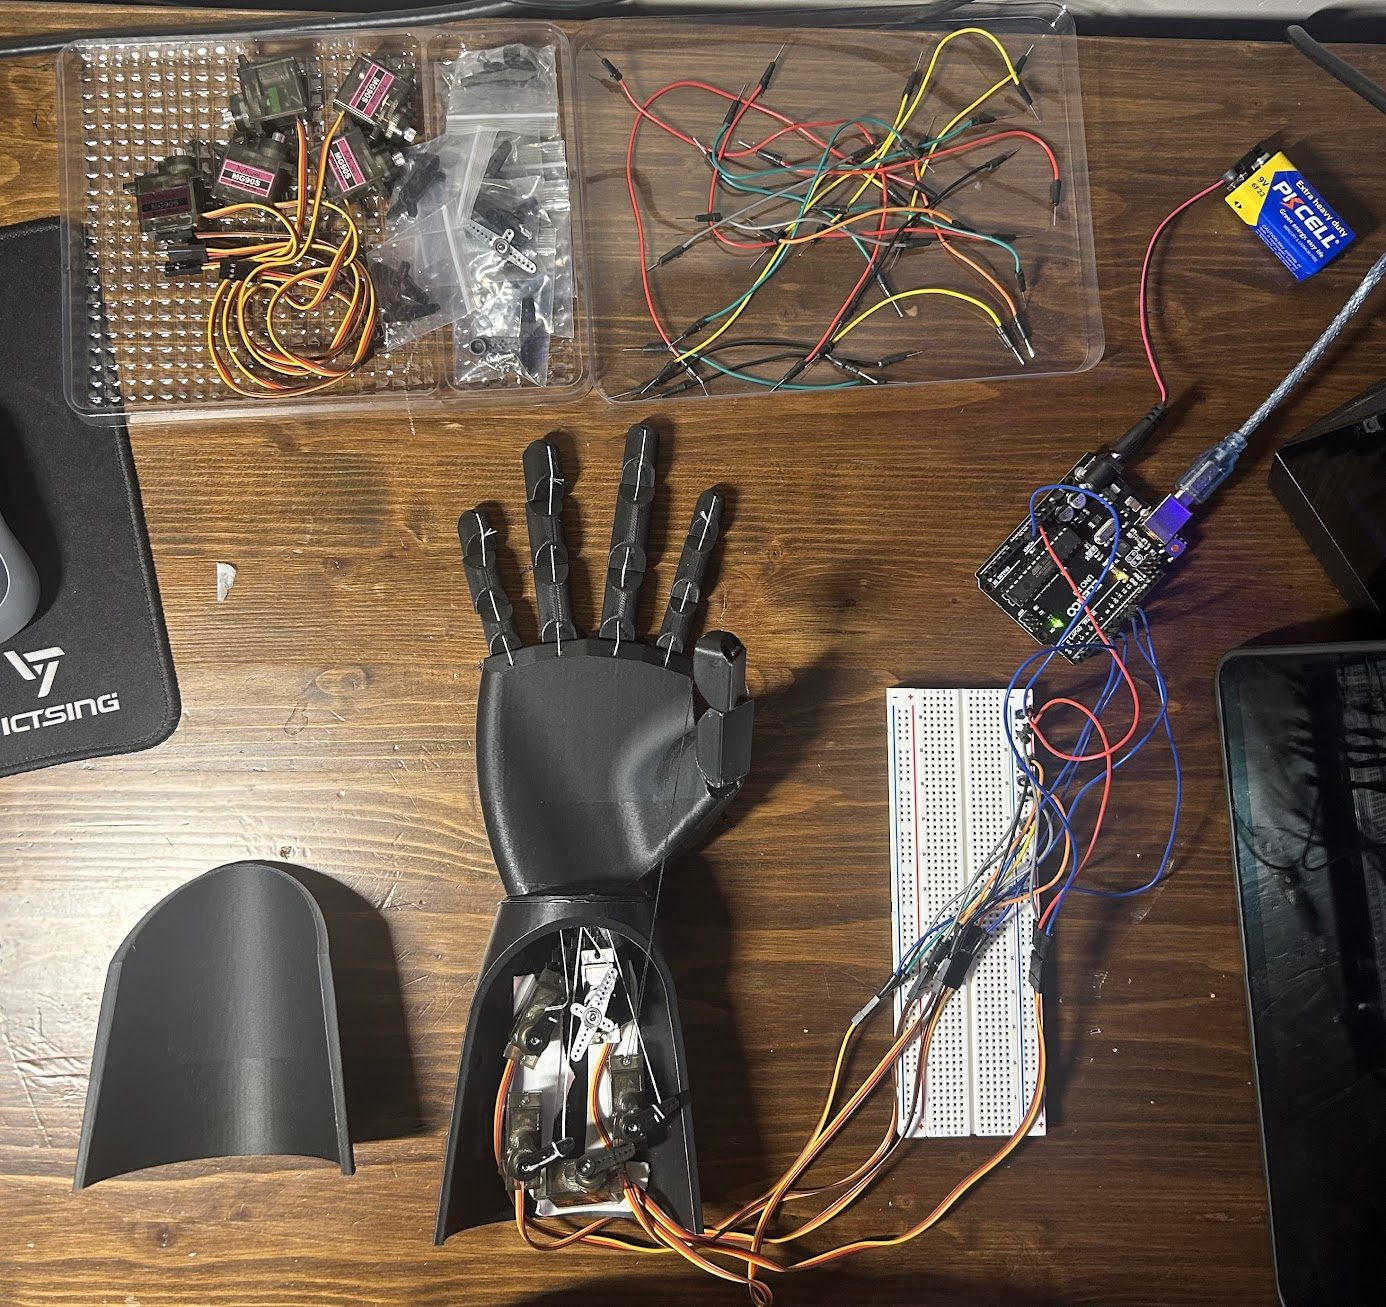
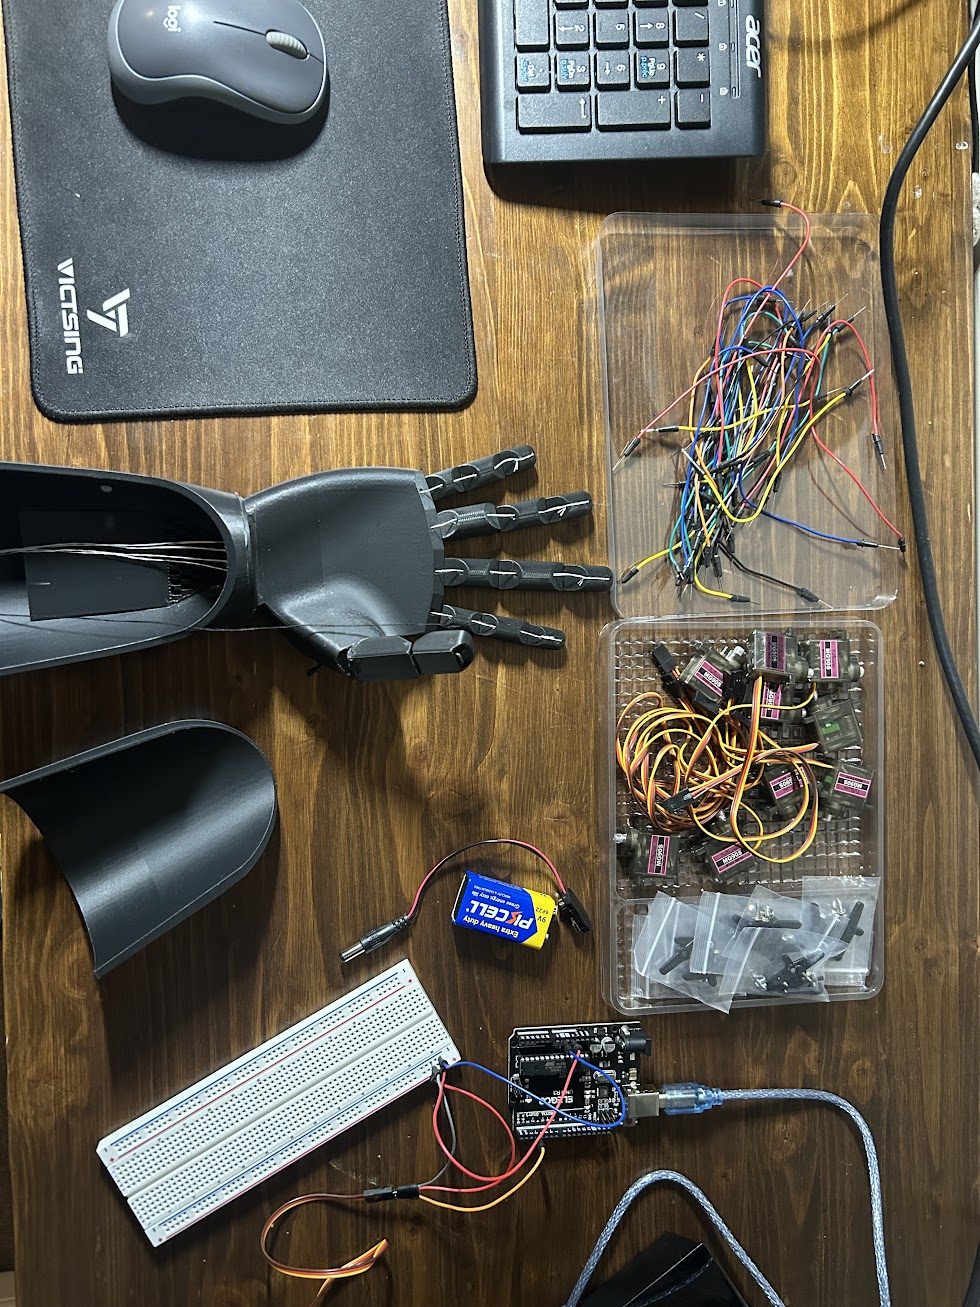
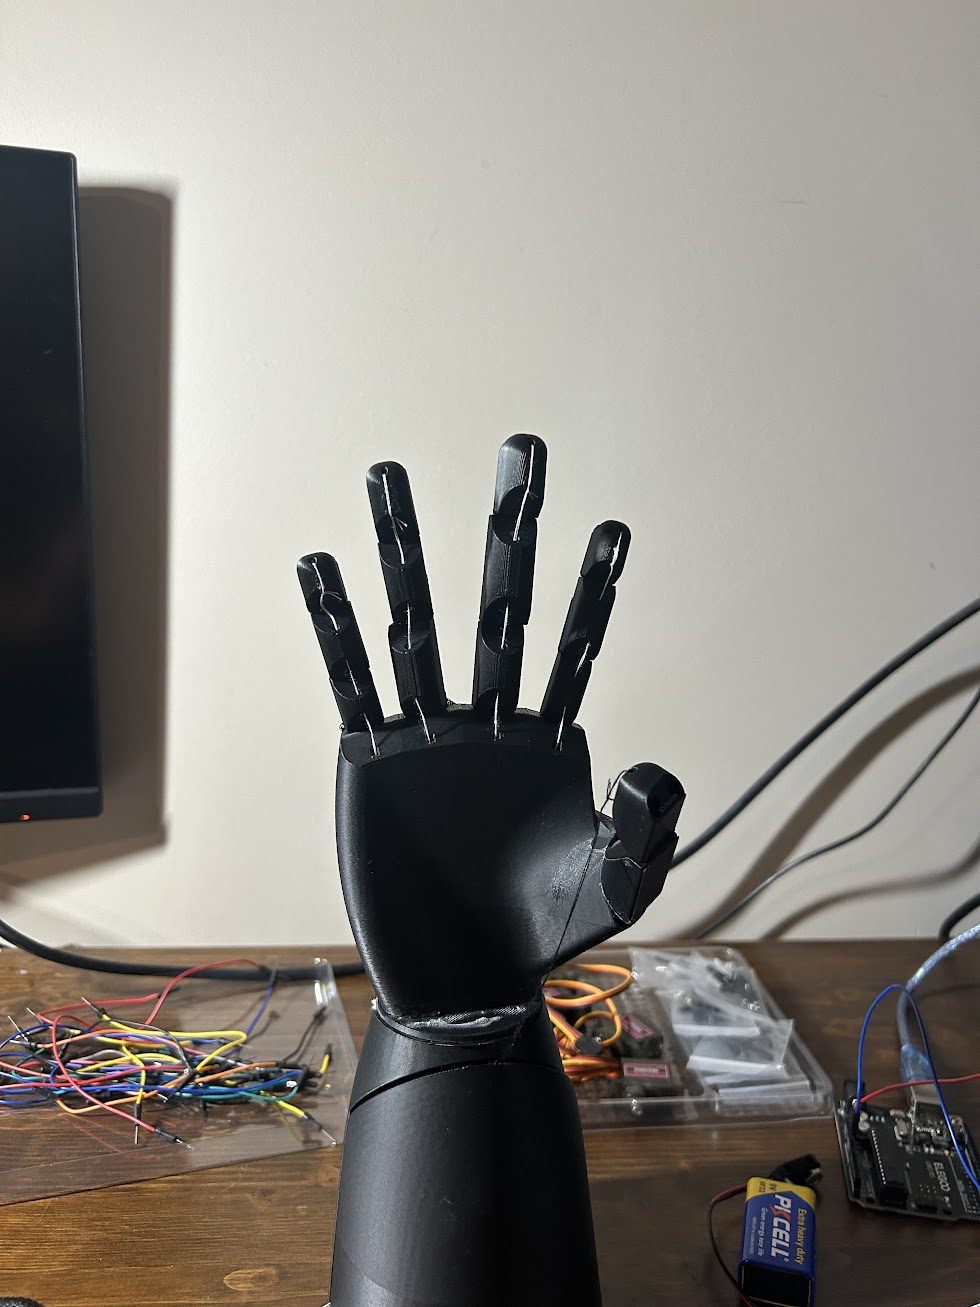
This project was built to gain a deeper understanding of what computer vision can do when paired with a physical robot. I designed the hand in SolidWorks and 3D printed it, with each of its five fingers driven by its own servo through a tendon that runs through the finger's joints. A webcam tracks the user's hand using MediaPipe and OpenCV, and after calibrating to that person's range of motion, a Python script calculates how bent each finger is from its joint angles. Those values are sent over serial to an Arduino Uno, which moves each servo so the robot's fingers mirror the user's in real time.
Design decisions and challenges
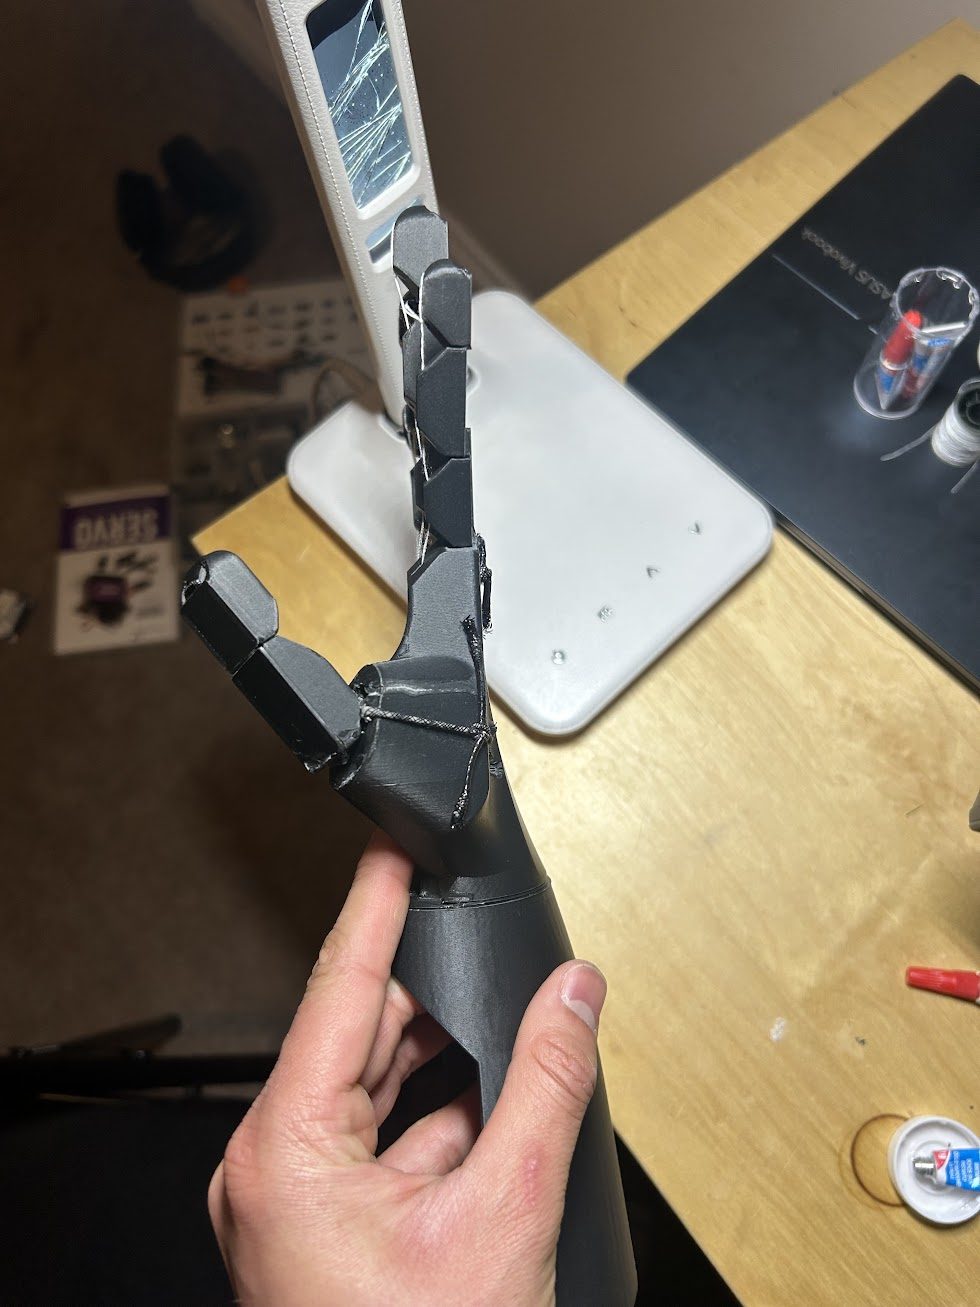
- Actuated each finger with a single servo instead of one per joint. A single tendon routed through every joint produces a natural curling motion, similar to a human finger, while keeping the hand down to five actuators.
- Designed the connecting end of each joint at an angle so the segments fold into each other smoothly under tension, instead of catching on one another.
- Compared several mathematical approaches for converting MediaPipe's landmark data into servo commands, and determined that calculating the angle at each finger joint gave the most accurate and consistent tracking.
- Added a calibration layer to the software instead of relying on hardcoded limits, since every user's hand is a different size and has a different range of motion.
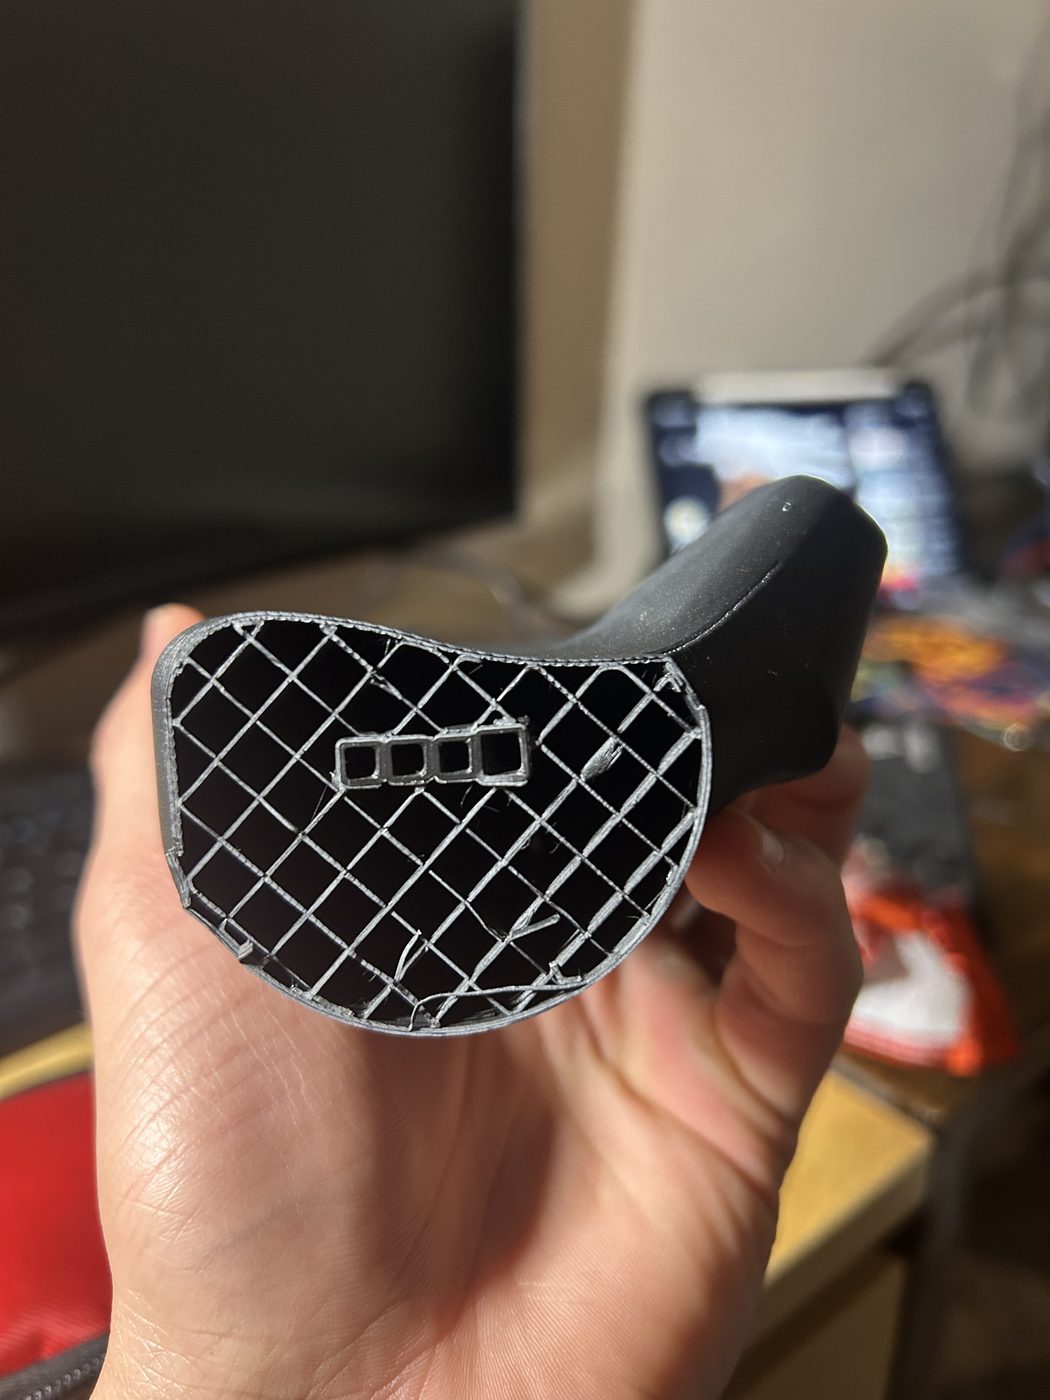
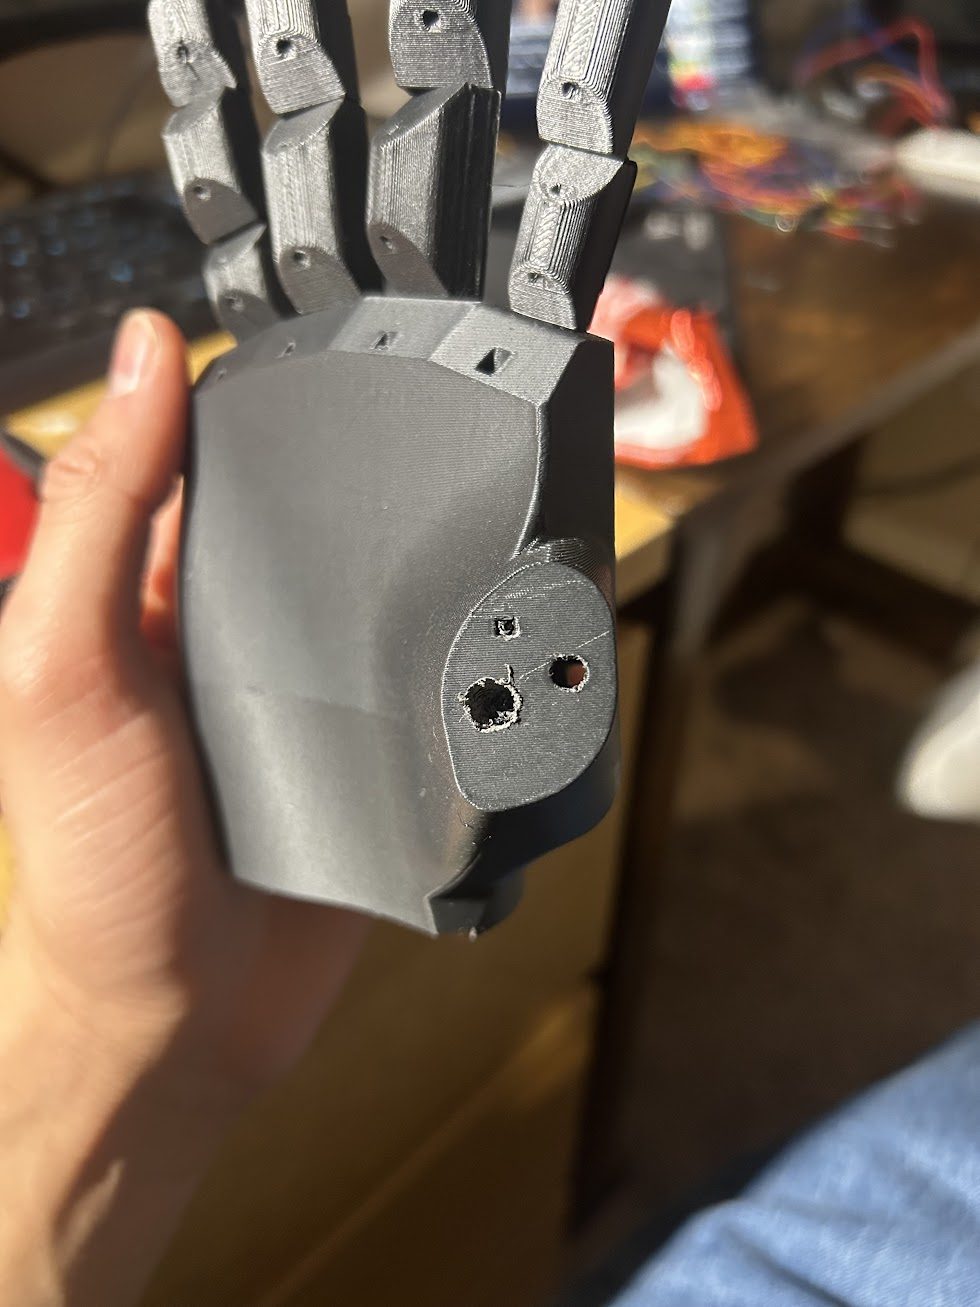
- Had difficulty routing the tendons through the fingers after assembly, since the printed parts left very little clearance to work in. I've since revised the design with larger tendon channels to make future assembly easier.
What I learned
Replicating a human hand is a lot more complex than it looks, and small details in the geometry and shape of each joint make a big difference in how naturally it moves. I also learned that there are several ways to turn MediaPipe's tracking data into servo commands, and the approach you choose has a big effect on how accurately the hand follows yours.
Build progress
Demo video
Wiring